The Rise of Doctor Octopus: Revolutionizing Robot Intelligence
In the world of robotics, a fascinating development is taking shape, and it's not just about mechanical arms and legs. Feagine Robotics has unveiled a groundbreaking concept, a 'Doctor Octopus' of sorts, with a brain that can adapt and learn across different robot bodies. This is a significant departure from the traditional approach, where robot AI is often tied to a specific physical structure.
Breaking the Intelligence Barrier
The core idea here is to create a foundation model, Fi0, that can retain task knowledge regardless of the robot's physical attributes. This is crucial as we move away from standardized industrial robots towards more diverse and specialized machines. The challenge lies in the robot's body itself, which dictates its capabilities and limitations.
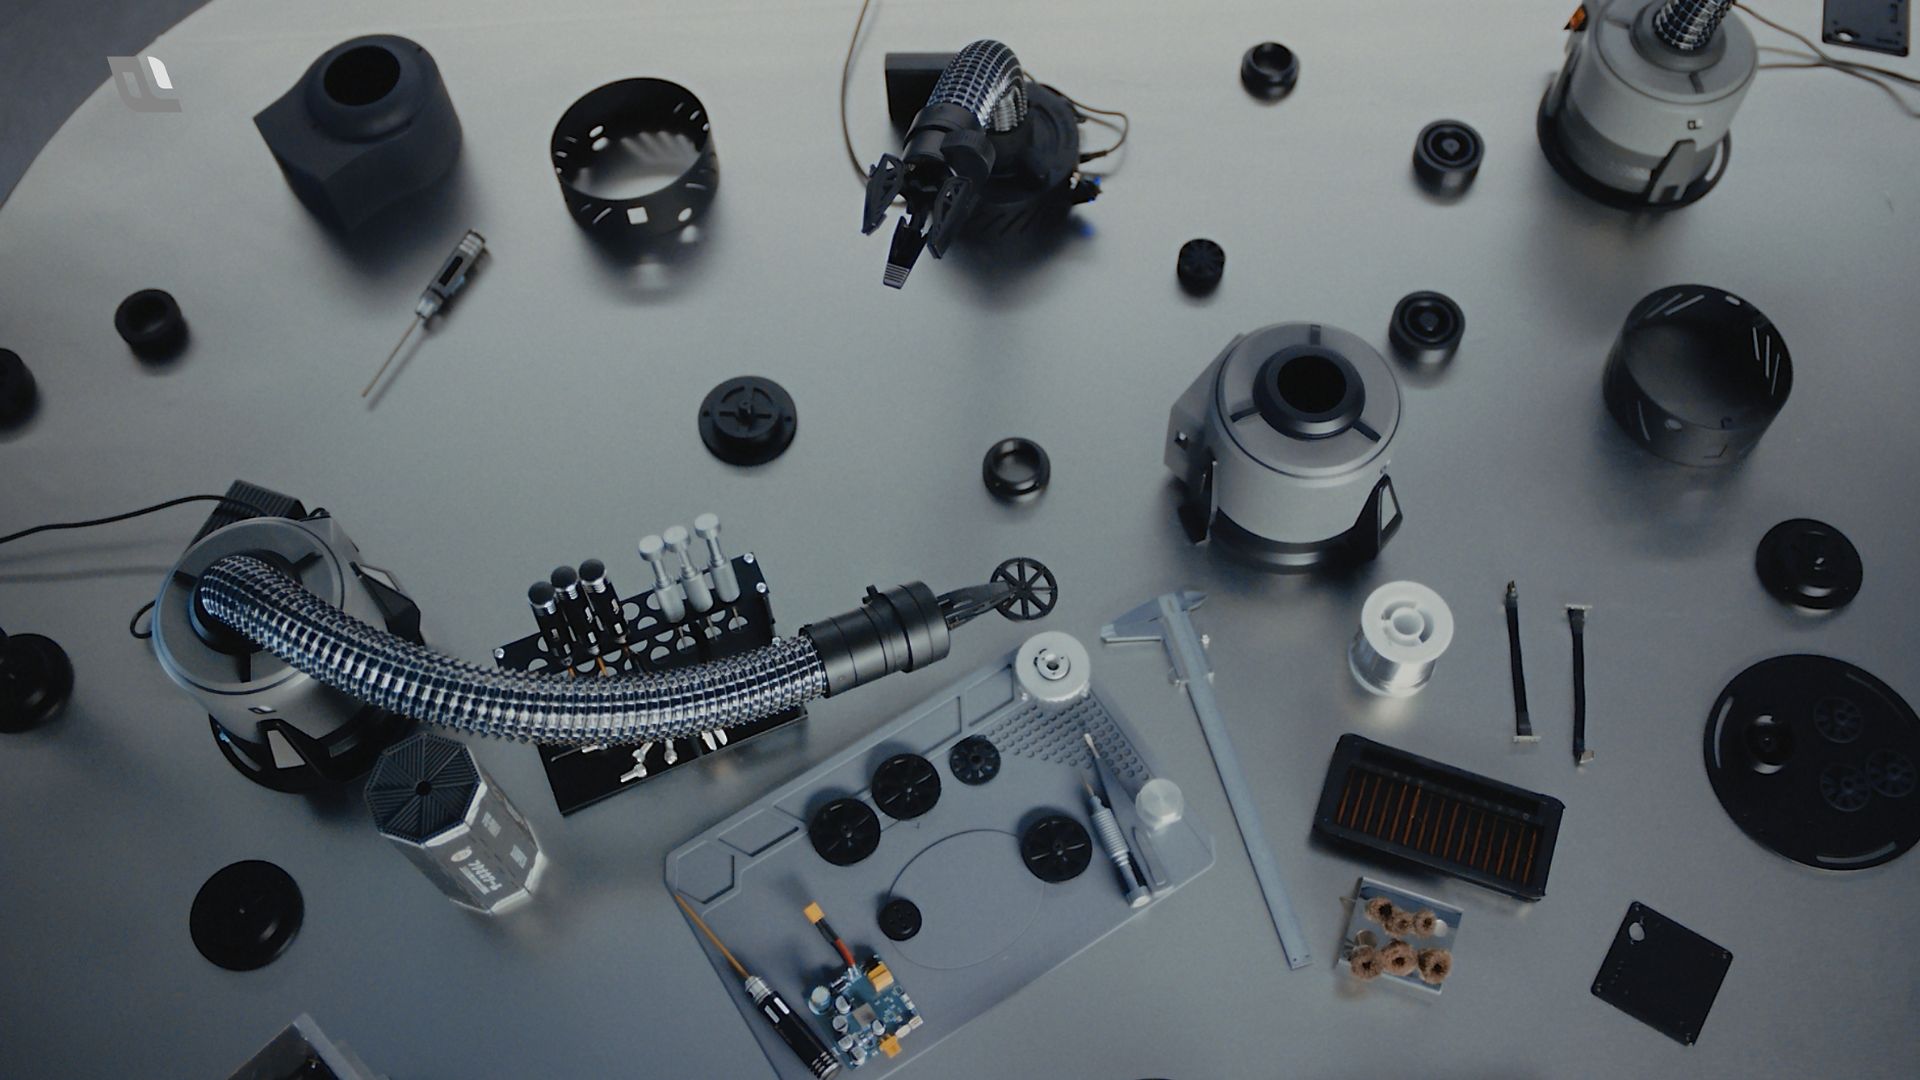
For instance, consider a simple arm. The number of segments and degrees of freedom determine its reach and flexibility. Feagine's solution is to introduce three unique manipulators, A01, A02, and A03, each with varying characteristics. This is where the real innovation shines. By representing the robot's physical structure and state as part of the decision-making process, Fi0 can adapt its actions accordingly.
Cross-Embodiment Intelligence: A Game-Changer
The concept of 'cross-embodiment' intelligence is what sets this apart. It allows the robot to understand that the task remains constant, even if the physical execution varies. This is a major leap from the conventional approach, where changing the robot often meant reprogramming its intelligence.
What's impressive is Feagine's demonstration of this concept. They propose that a single human demonstration can teach Fi0 a new task, without the need for extensive retraining. The model interprets the demonstration, focusing on the task's essence rather than the human's exact movements. This is a significant step towards more adaptable and intuitive robot learning.
Soft Robots: A Complex Challenge, A Valuable Test
Feagine's choice of soft, tendon-driven manipulators is not arbitrary. These robots present a unique challenge due to their continuous bending and shape-shifting abilities. This complexity is precisely why they are an excellent testbed for Fi0. The AI must understand the robot's physical configuration as part of the problem-solving process.
The 'Embodiment Graph' is a brilliant solution, incorporating the robot's morphology, sensing, and actuation. This allows the AI to not just react to the environment but also predict and interpret actions. The term 'soft embodied intelligence' perfectly encapsulates this fusion of hardware and software.
Beyond Humanoids: A Diverse Future for Robotics
The implications of this technology are vast. It challenges the notion that general-purpose intelligence requires a humanoid form. Instead, Feagine asks, can one intelligence control multiple specialized bodies? This is a paradigm shift, focusing on the adaptability of the AI rather than the versatility of the hardware.
While Fi0 is still in its early stages, the potential is evident. If successful, it could mean a future where a single intelligent system operates a diverse range of robots, each tailored for specific tasks and environments. This could revolutionize industries, from manufacturing to healthcare, by providing adaptable, specialized solutions.
In conclusion, Feagine's 'Doctor Octopus' robots represent a bold step towards more flexible and intelligent robotics. They challenge the status quo, showing that the future of AI may not be about creating a universal robot but rather a versatile intelligence that can navigate a family of specialized machines. This is a fascinating direction, one that I believe will shape the next era of robotics and AI.